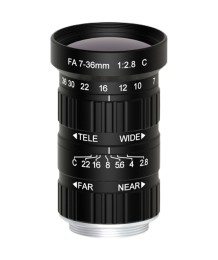
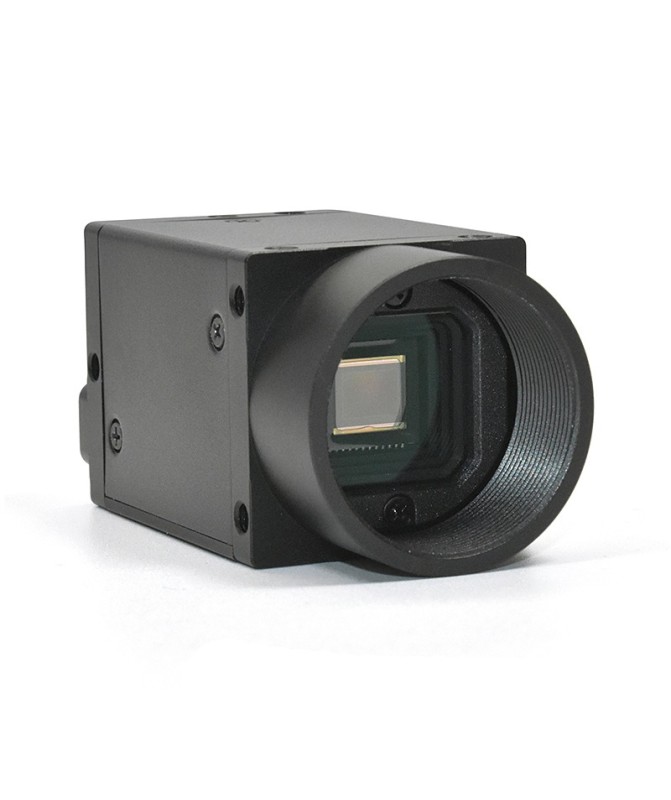
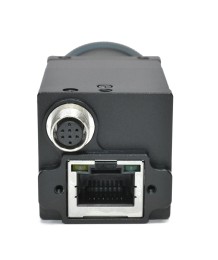
Technical specifications:
Model: HT-GE134GC-T1P-C
- Interface: Gigabit Ethernet (RJ-45)
- Lens mount: C-mount
- I/O: 6-pin circular connector – power, Trigger In, Strobe/Output
- Resolution (series "134"): approx. 1.3 MP (e.g. 1280×1024)
- Frame rate: up to ~30 fps (depending on settings)
- Power supply: 12–24 VDC via 6-pin connector
- Software/SDK: compatible with GigE camera platforms (e.g. GigE Vision/GenICam)
- Housing: metal, with mounting threads
Package includes:
- Industrial camera HT-GE134GC-T1P-C
- Power + I/O cable
The camera is GigE Vision class and is typically compatible with GenICam (GenApi, GenTL). This allows operation with a wide ecosystem of tools without vendor lock-in.
Supported OS and languages:
- Operating systems: Windows 10/11 (x64), Linux (Ubuntu/Debian/RedHat variants, x64)
- Languages and API: C/C++, C#/.NET, Python (via GenTL/SDK bindings), LabVIEW
- Frameworks/libraries: OpenCV, HALCON, MATLAB, Cognex VisionPro, MVTec, ROS/ROS2 (via image_transport/Aravis/Harvester), GStreamer.
What the SDK includes:
- Device discovery (over network, across subnets), reading/writing parameters via GenApi.
- Stream/Grab engine: packet size configuration, jumbo frames, packet delay, resend on loss, ring buffer, multi-camera operation
- Triggers and I/O: software trigger, hardware trigger (input from 6-pin connector), programmable strobe/output; debounce/pulse width (if supported by the model).
- Exposure and gain: auto/manual exposure, gain, white balance (auto/manual), gamma, LUT.
- Region of Interest (ROI), binning/decimation for increased FPS.
- Color/demosaicing: Bayer→RGB/Gray, color conversion in SDK, optional GPU acceleration (if available).
- Events/Callbacks: frame events, exposure end, I/O events; timestamps and framing with PTP (IEEE-1588) for network synchronization (if available in the model).
- Recording/export: recording sequences/frames in RAW/BMP/PNG/JPEG/TIFF; RAM disk/stream writer.
- Diagnostics: statistics for lost packets, bandwidth monitor, logs.
- GenTL Producer: for integration with third-party applications (HALCON, MATLAB, Harvesters/Aravis, etc.).
- Examples and project templates: C++, C#, Python (basic grab, software trigger, save to disk, color convert).
Minimum system requirements:
- CPU: dual-core or better (i5/Ryzen 5+ recommended)
- RAM: 8 GB (16 GB recommended for real-time recording/processing)
- LAN: Gigabit port (Intel/Realtek); for full FPS – dedicated NIC, Jumbo Frames enabled.
- Cable: Cat5e/6, length up to 100 m; for PoE – compatible PoE switch/injector (if used).
Quick start (Windows/Linux):
- Install SDK/driver (including GenTL Producer).
- Connect the camera to the Gigabit NIC. (Optional – separate switch/interface for machine vision only.)
- In the SDK configurator: set IP (DHCP/Static), MTU/Jumbo Frames (e.g., 9000).
- Test live stream ("Acquisition/Grab") and save a test frame.
- Configure Trigger Mode (Off/On), Exposure/Gain, Pixel Format (Mono8/BayerRG8/RGB8).
- Connect the 6-pin connector as needed (power, trigger, strobe)
Third-party compatibility:
- HALCON – automatically recognized via GenTL Producer.
- LabVIEW – via IMAQdx (GigE Vision) or vendor driver.
- MATLAB – Image Acquisition Toolbox (GigE Vision adapter).
- OpenCV – via GenTL/SDK grab + cv::Mat conversion; direct via VideoCapture is usually insufficient for GigE Vision.
- ROS/ROS2 – drivers based on Aravis/Spinnaker/Harvesters; publishing sensor_msgs/Image.
Technical specifications:
Model: HT-GE134GC-T1P-C
- Interface: Gigabit Ethernet (RJ-45)
- Lens mount: C-mount
- I/O: 6-pin circular connector – power, Trigger In, Strobe/Output
- Resolution (series "134"): approx. 1.3 MP (e.g. 1280×1024)
- Frame rate: up to ~30 fps (depending on settings)
- Power supply: 12–24 VDC via 6-pin connector
- Software/SDK: compatible with GigE camera platforms (e.g. GigE Vision/GenICam)
- Housing: metal, with mounting threads
Package includes:
- Industrial camera HT-GE134GC-T1P-C
- Power + I/O cable